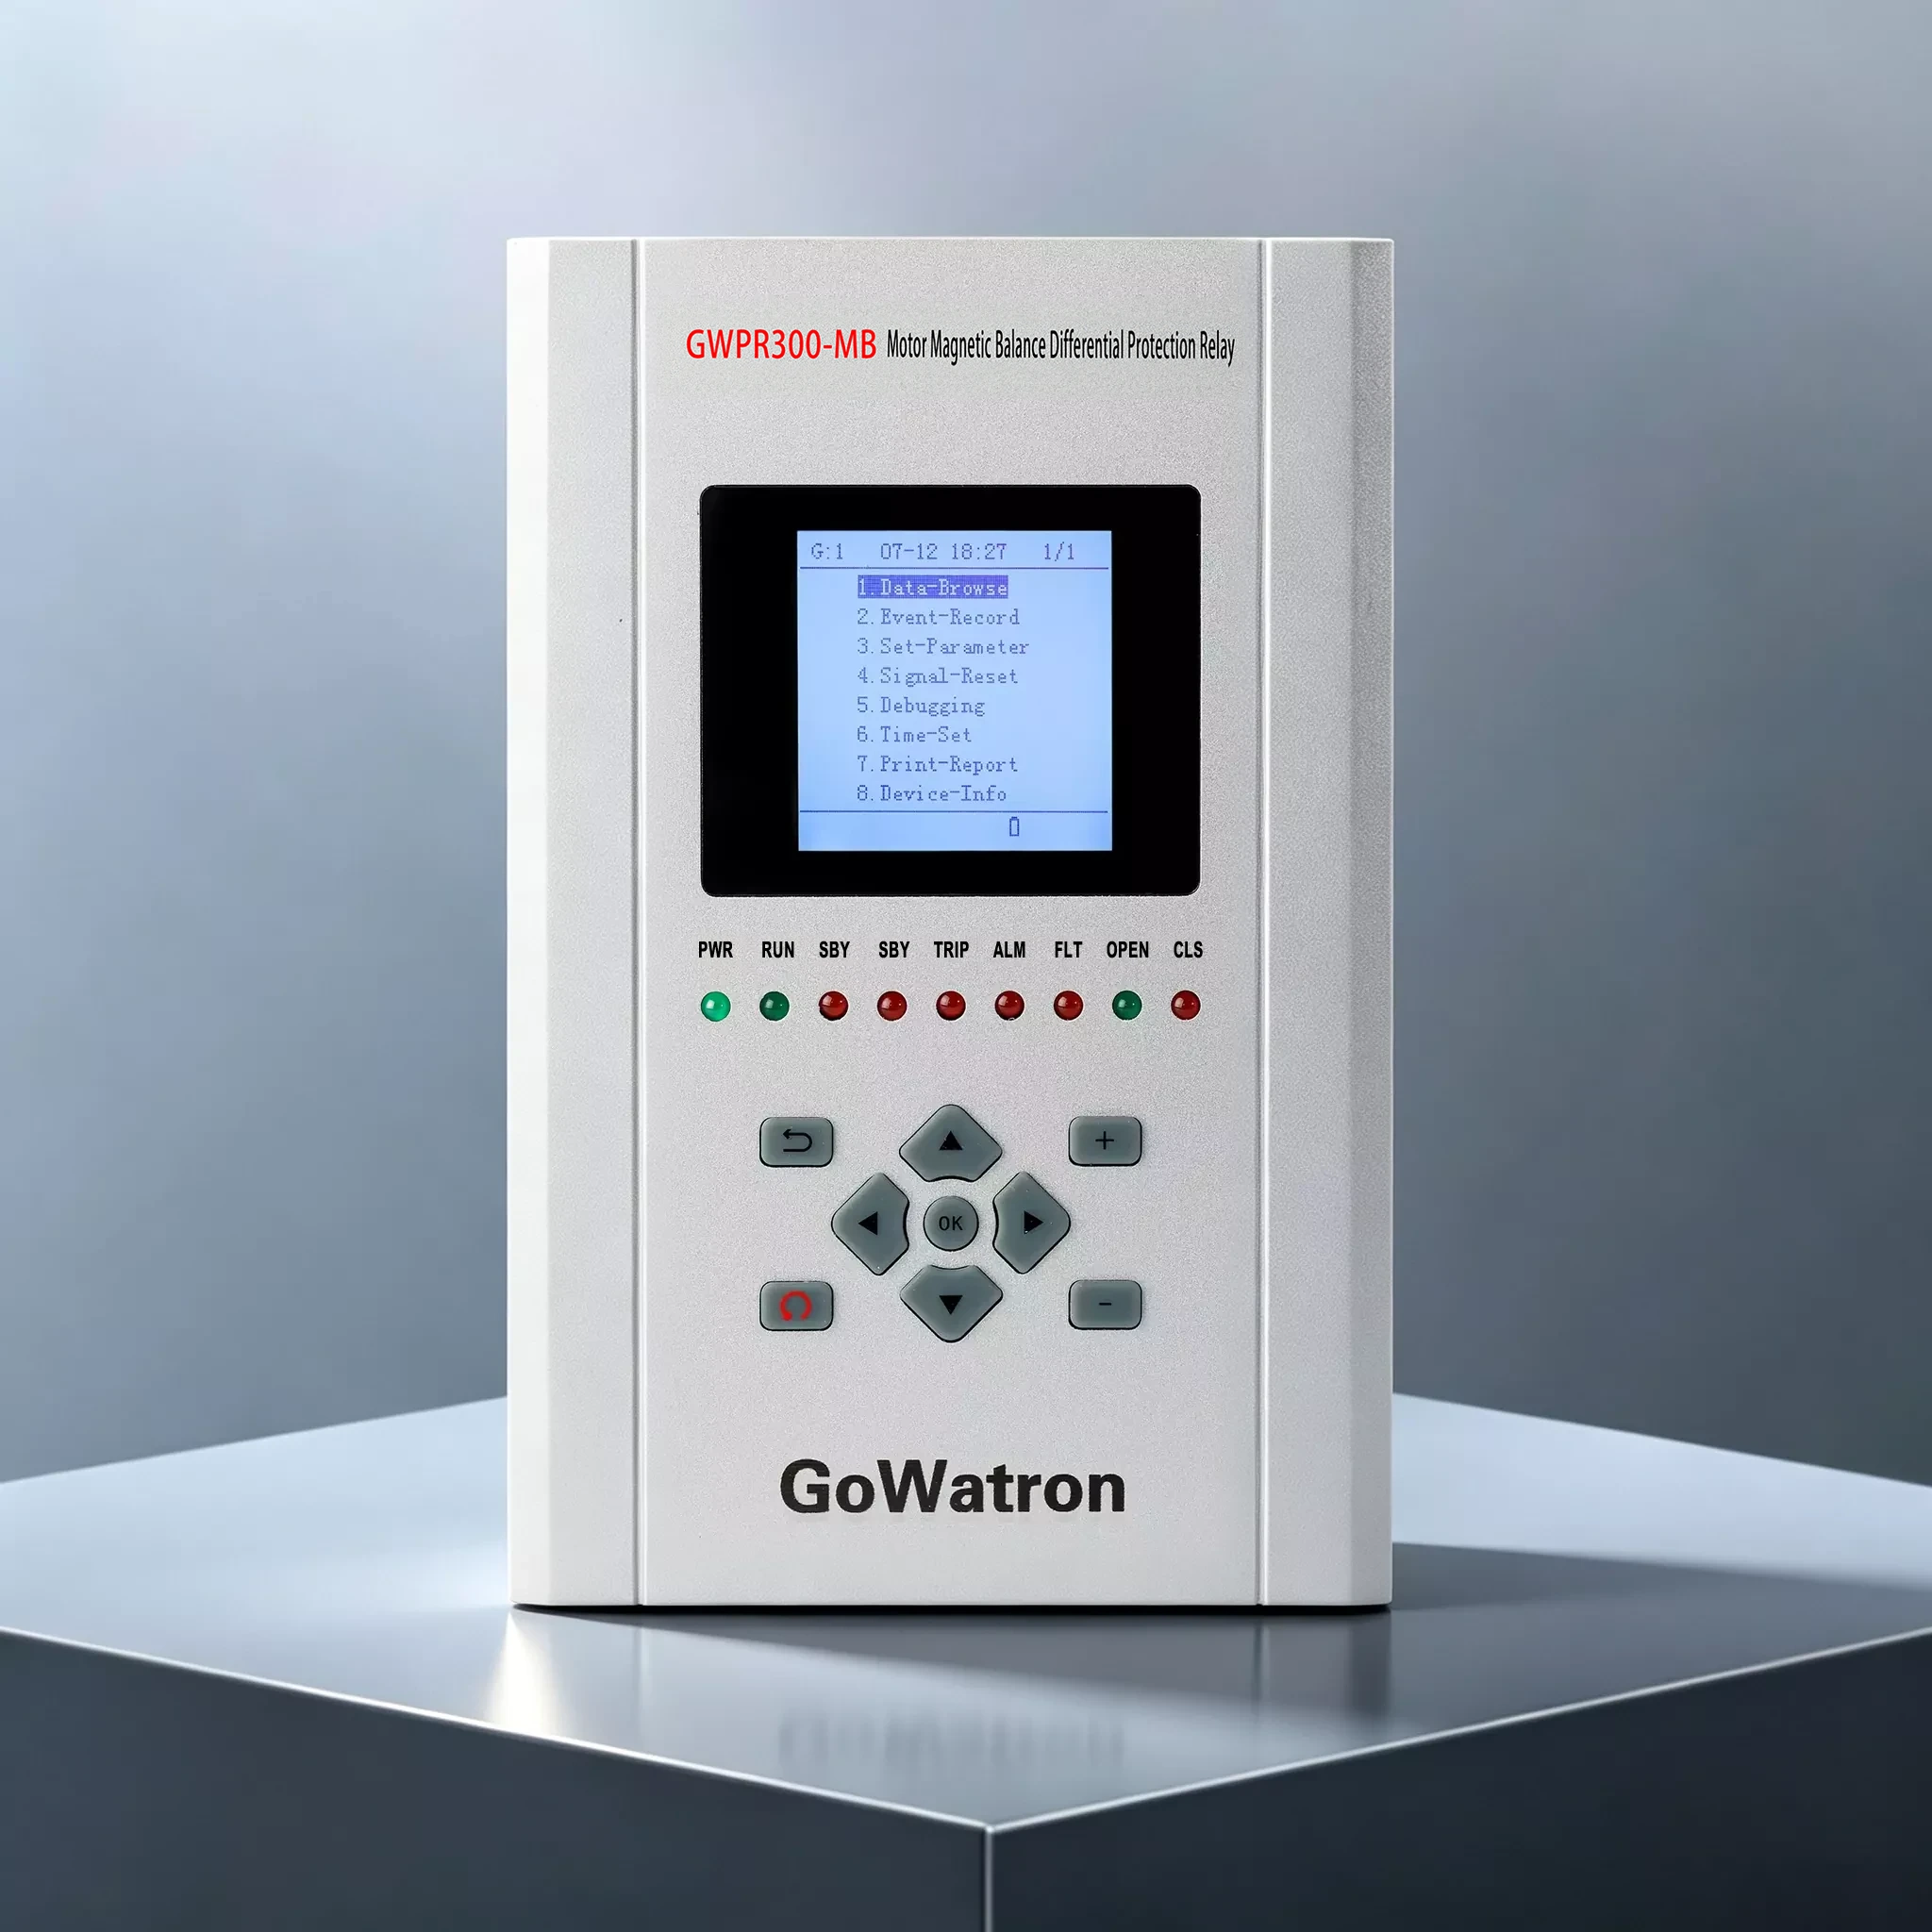
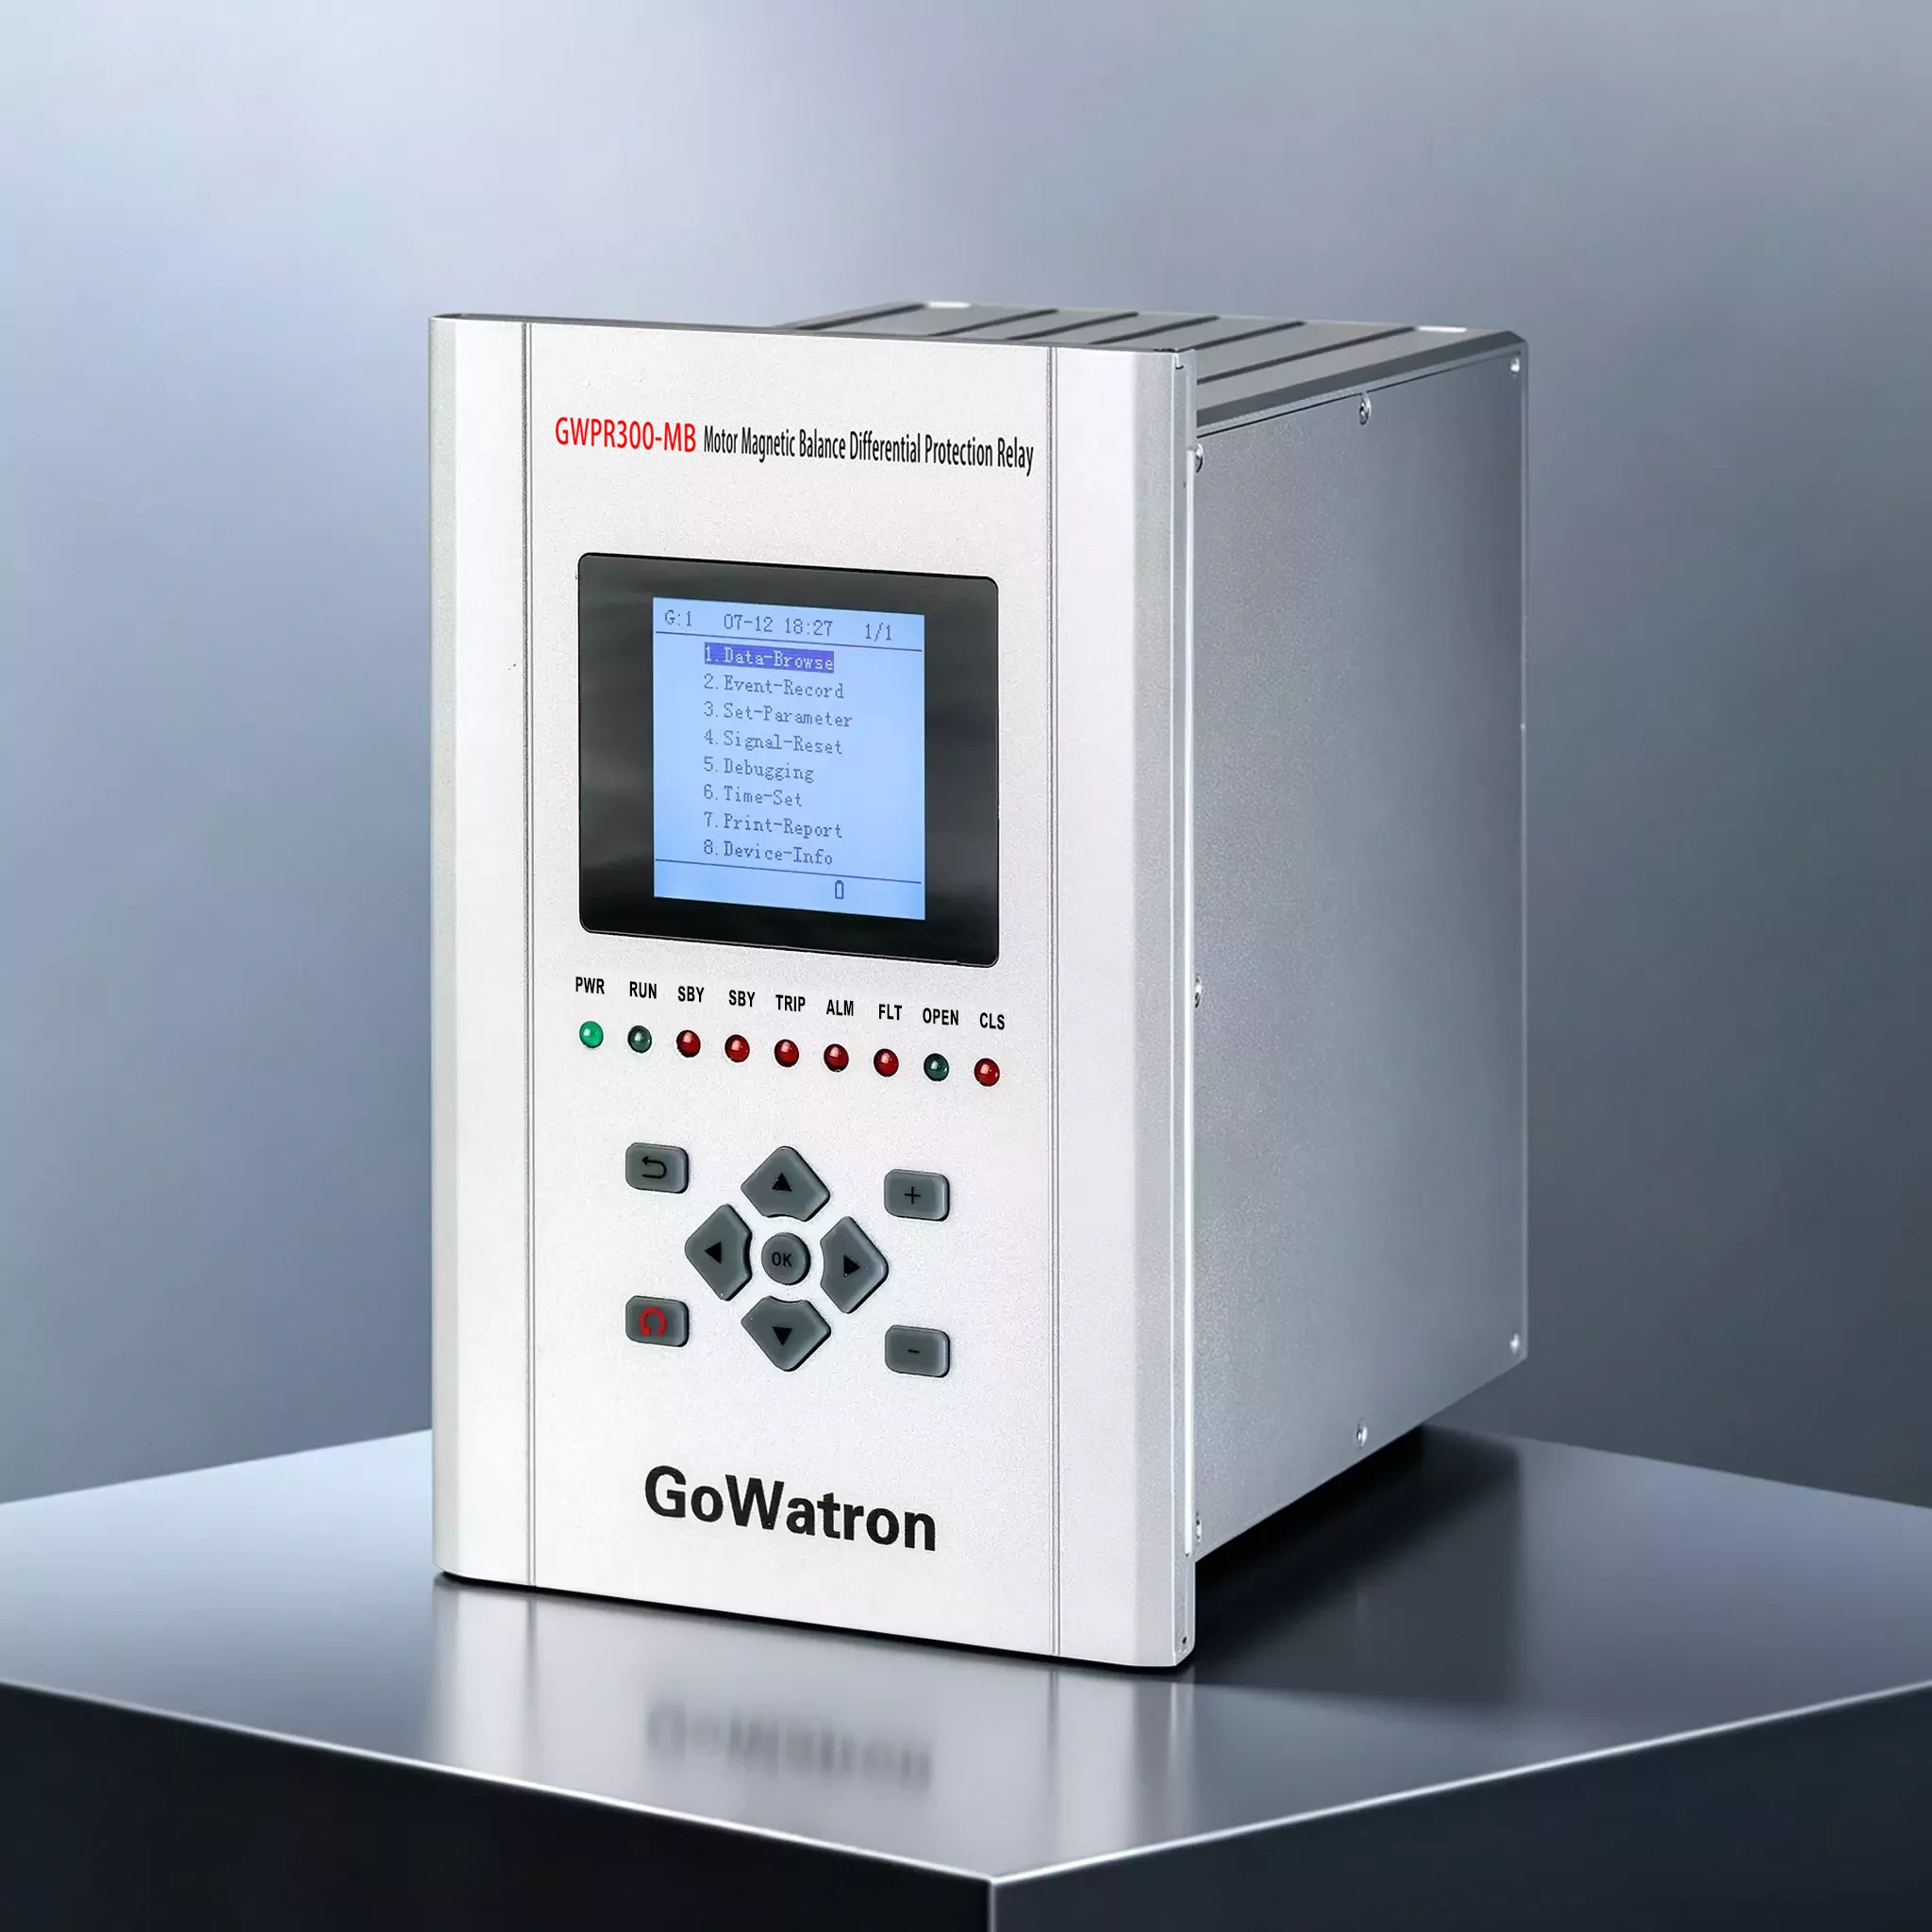
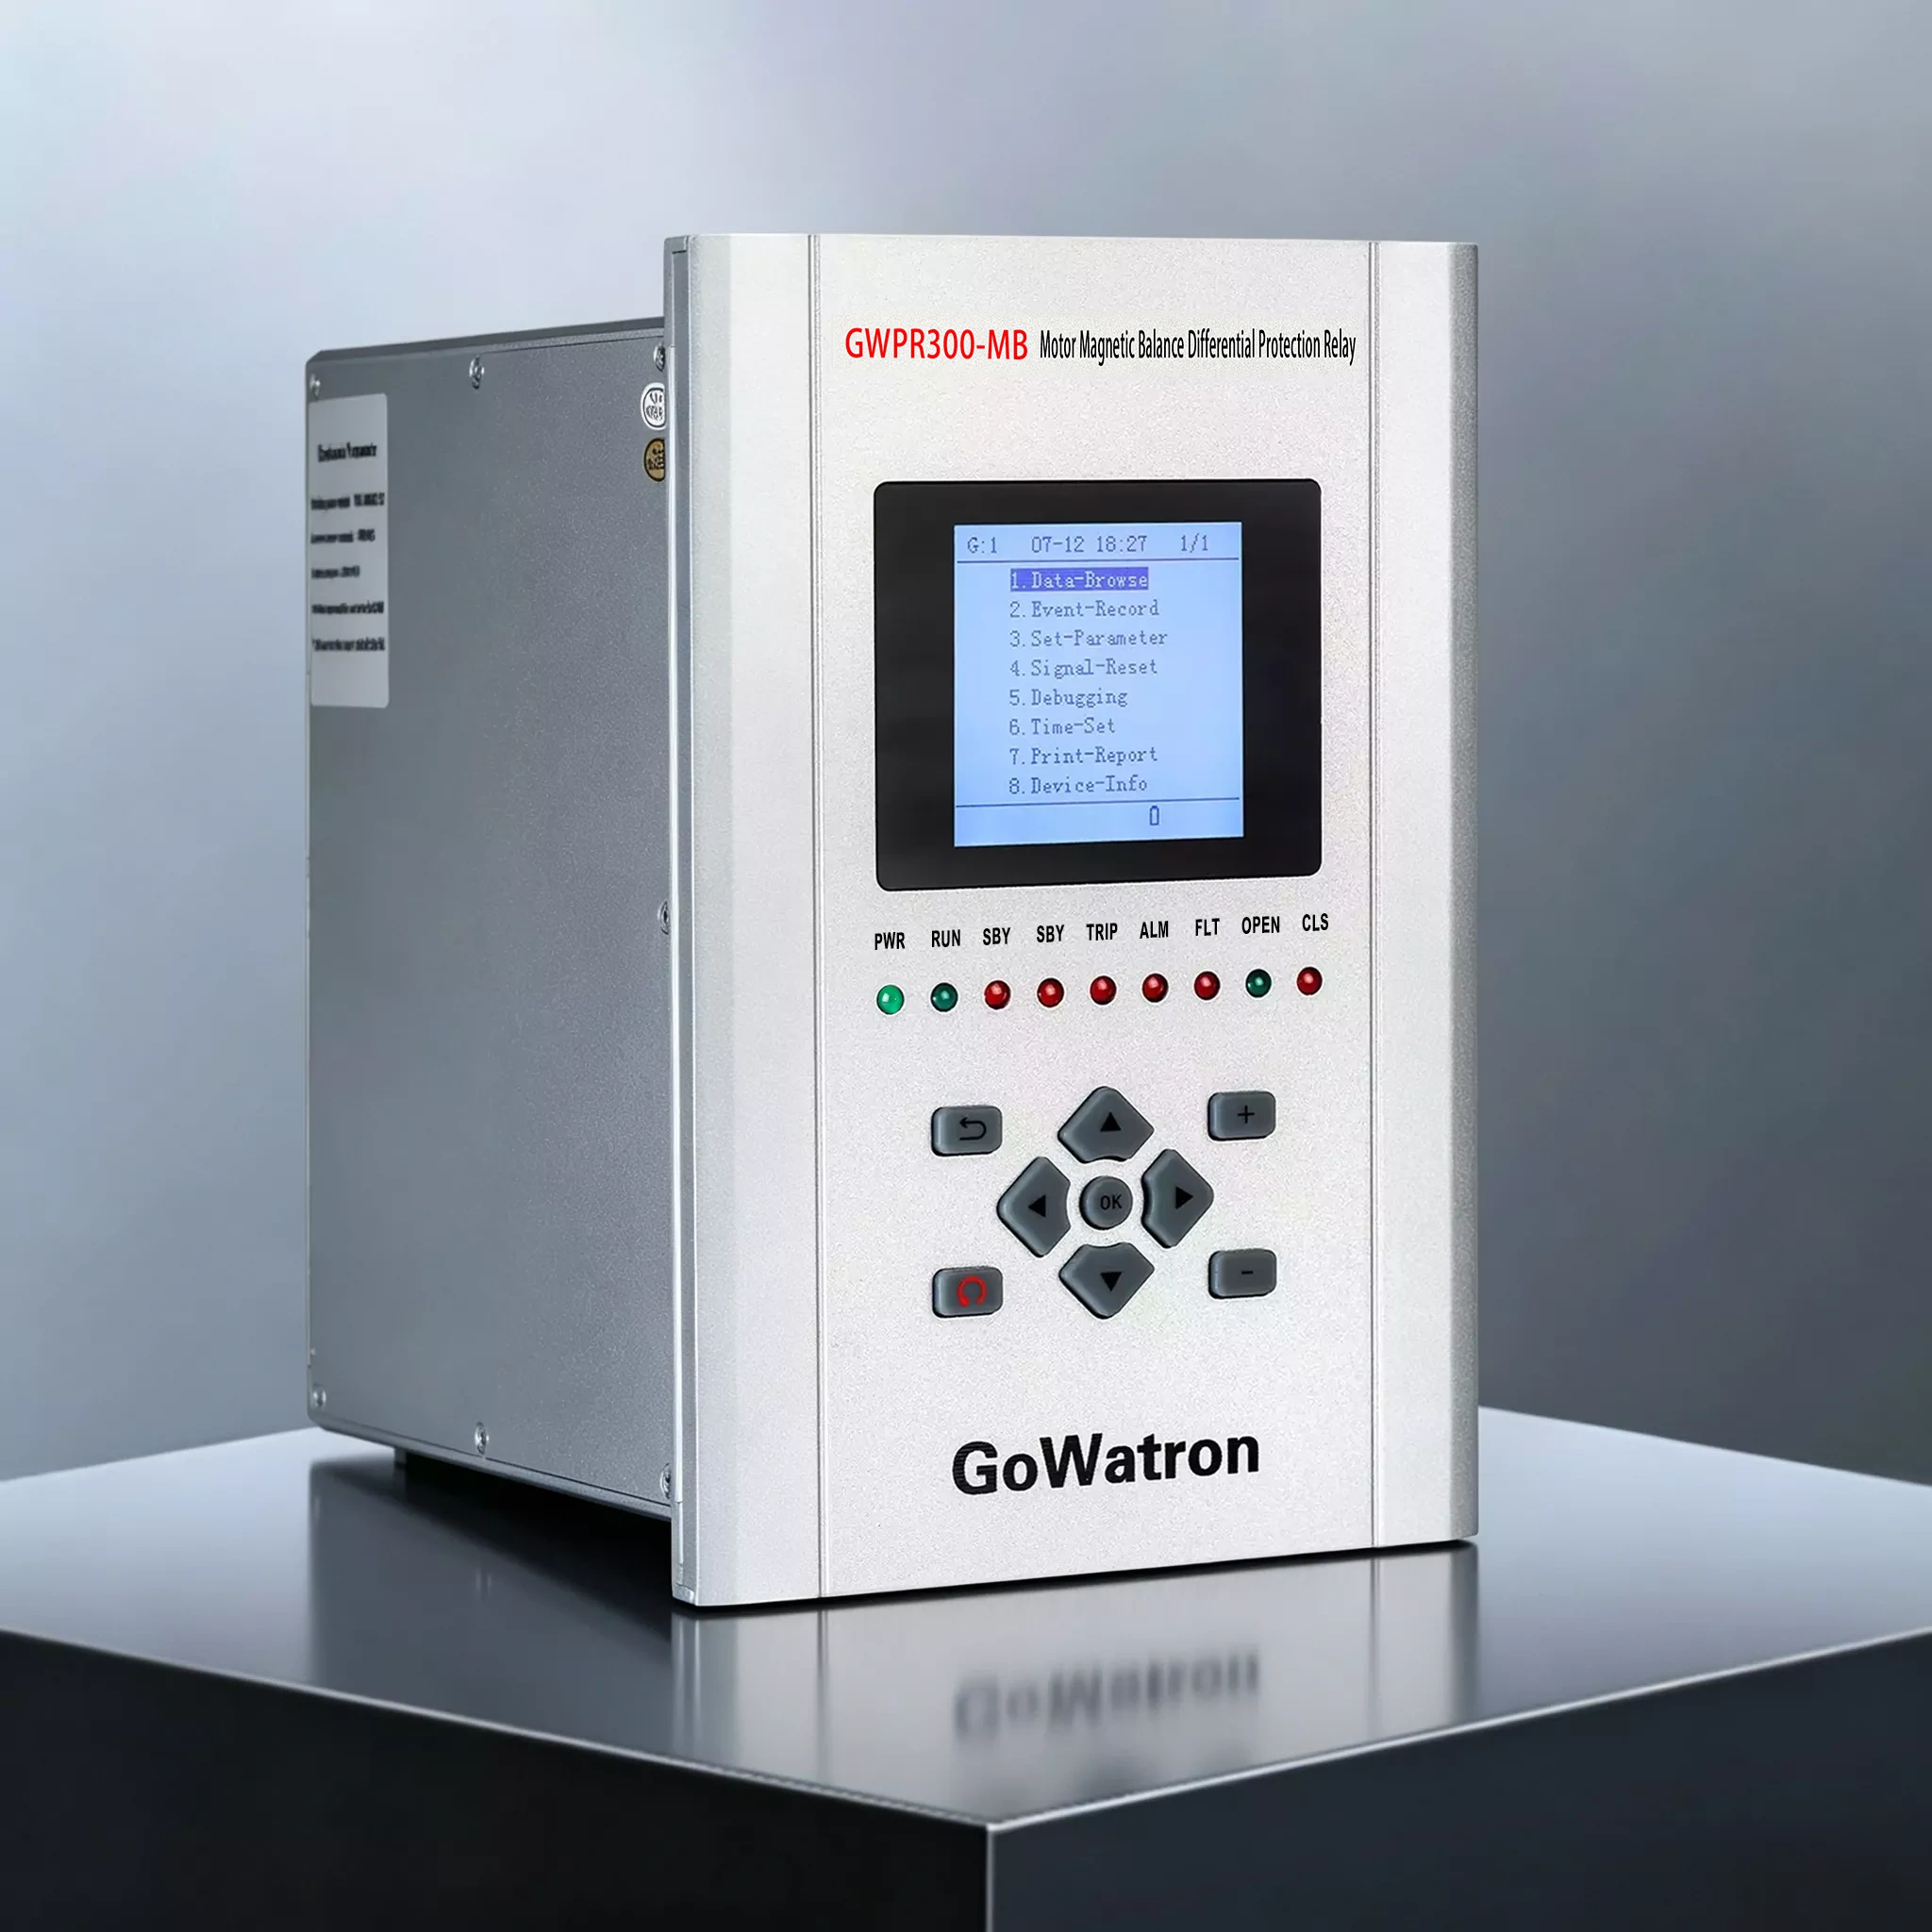
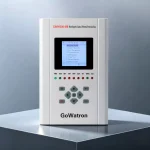
GWPR300-MBD Motor Magnetic Balance Differential Protection Relay
The GWPR300-MBD Motor Magnetic Balance Differential Protection Relay is a numerical protection and control relay designed by GoWatron specifically for high- and low-voltage induction motors. It integrates protection, measurement, control, communications, and disturbance recording functions. The relay can be installed in a centralised protection panel or locally in a switchgear cubicle.
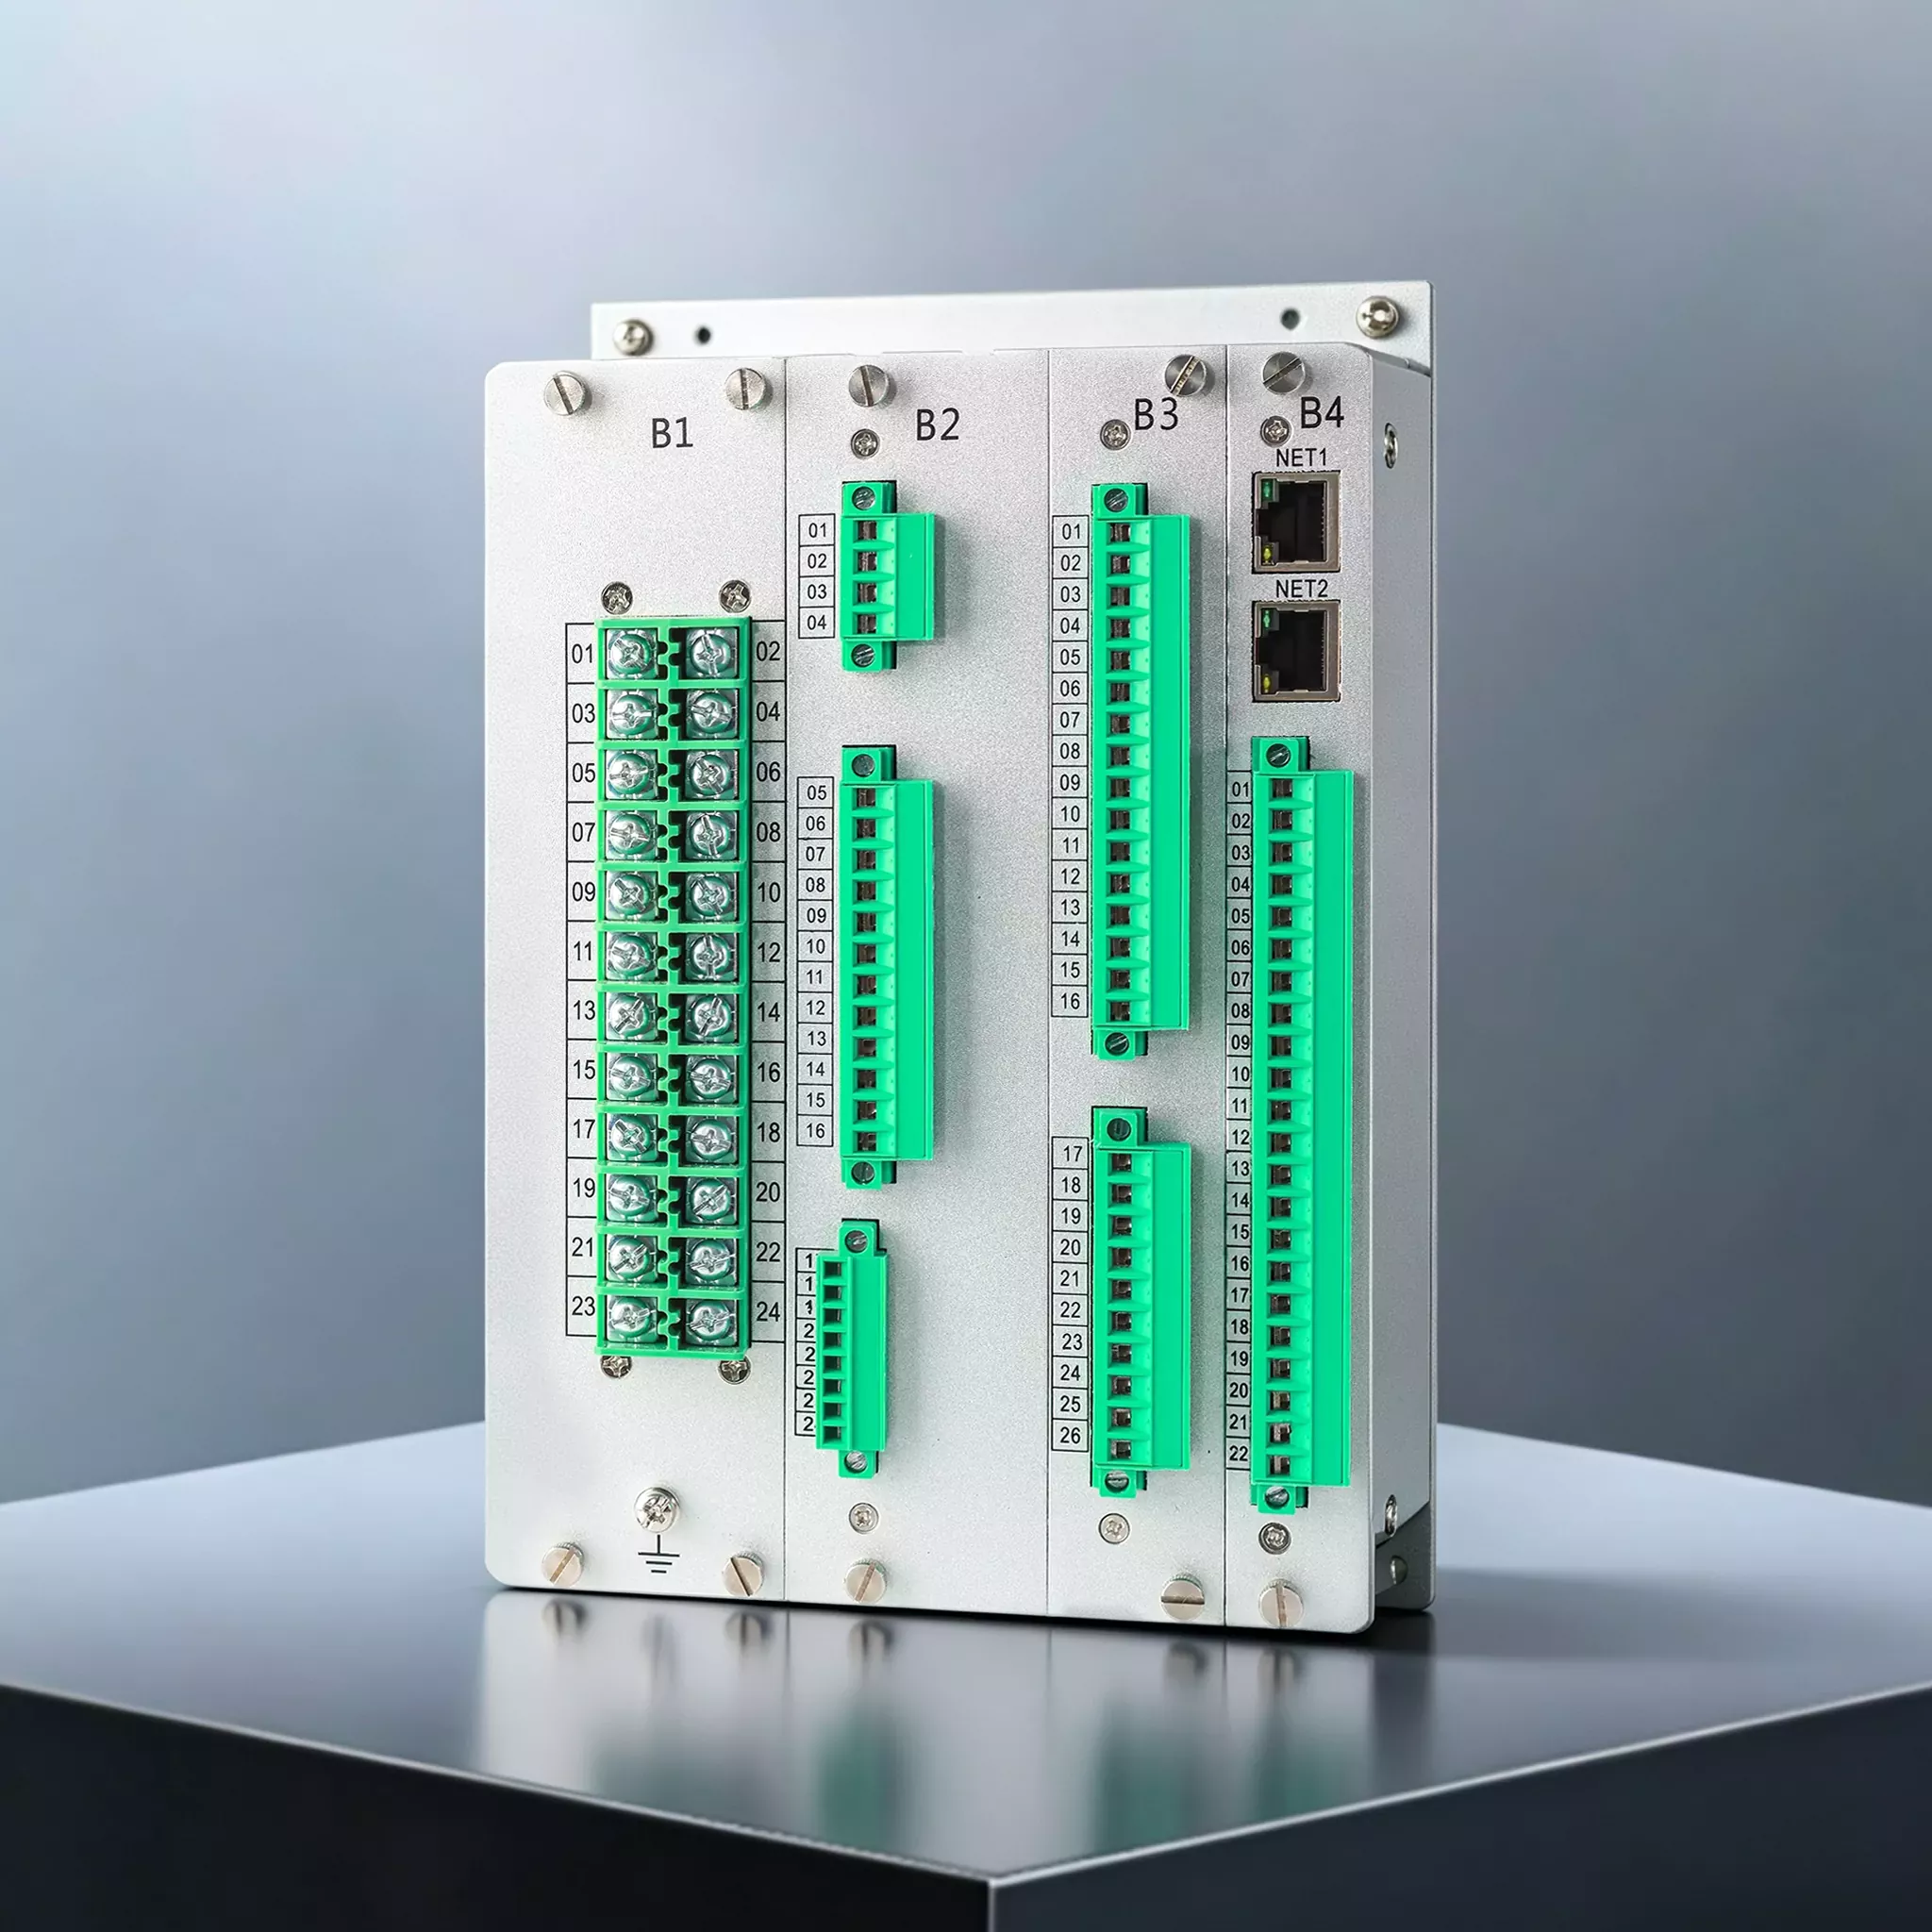
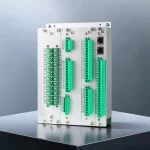
- The relay provides two RS-485 interfaces supporting Modbus RTU communication, one of which shares its connection with the time synchronisation interface. This shared interface can be configured for either serial communication or time synchronisation, while other communication and time synchronisation functions remain available as supported by the device configuration.
- It is equipped with dual Ethernet ports (supporting the IEC 60870-5-103 over Ethernet protocol, with optional IEC 60870-5-104 or IEC 61850 protocols).
- It supports time synchronisation via communication messages, SNTP, or IRIG-B.



1.Protection Functions
- (ANSI 87M) Magnetic Balance Differential Protection (Trip).
- (ANSI 50/51) Three-Stage Phase Overcurrent Protection — Stages I, II, and III (Trip; Stage I is not blocked during motor starting, while Stages II and III are activated after the motor start-up is completed).
- (ANSI 51) Inverse-Time Phase Overcurrent Protection (Trip; Standard Inverse, Very Inverse, and Extremely Inverse curves selectable).
- (ANSI 51) Definite-Time Overload Protection (Alarm or Trip selectable, based on definite-time current criteria).
- (ANSI 51LR) Locked-Rotor Protection (Trip).
- (ANSI 46) Negative-Sequence Overcurrent Protection – Stage 1 (Trip, used for phase failure/open-phase protection).
- (ANSI 46) Negative-Sequence Overcurrent Protection – Stage 2 (Alarm or Trip selectable, used for unbalance protection).
- (ANSI 46) Inverse-Time Negative-Sequence Overcurrent Protection (Trip; Standard Inverse, Very Inverse, and Extremely Inverse curves).
- (ANSI 50N/51N) Zero-Sequence Overcurrent Protection (Alarm or Trip selectable; for motor stator earth-fault detection).
- (ANSI 49) Thermal Overload Protection (Alarm or Trip selectable; based on the IEC 60255-8 thermal model).
- (ANSI 48) Excessive Starting Time Protection (Trip).
- (ANSI 66) Motor Start Interval Supervision (Normally closed output, blocks motor starting).
- (ANSI 27) Undervoltage Start Inhibition (Normally closed output).
- (ANSI 59) Overvoltage Protection (Trip).
- (ANSI 27) Undervoltage Protection (Trip).
- (ANSI 59N) Zero-Sequence Overvoltage Protection (Alarm or Trip selectable).
- (ANSI 81O) Overfrequency Protection (Trip; optional undervoltage and rate-of-change of frequency blocking).
- (ANSI 81U) Underfrequency Protection (Trip; optional undervoltage and rate-of-change of frequency blocking).
- VT Circuit Failure Supervision (Alarm).
- VT Loss-of-Voltage Supervision (Alarm).
- Circuit Breaker Position Discrepancy Supervision (Alarm; detects inconsistencies between circuit breaker open and closed position signals).
- (ANSI 27) Loss-of-Supply Protection (Combined logic involving current and circuit breaker position criteria; Alarm or Trip selectable).
- Non-electrical Protection (2 channels, Alarm or Trip selectable).
- (Note: The default operation mode and output configuration of each protection function are subject to the factory settings. Protection outputs can be adjusted via the output configuration matrix.)
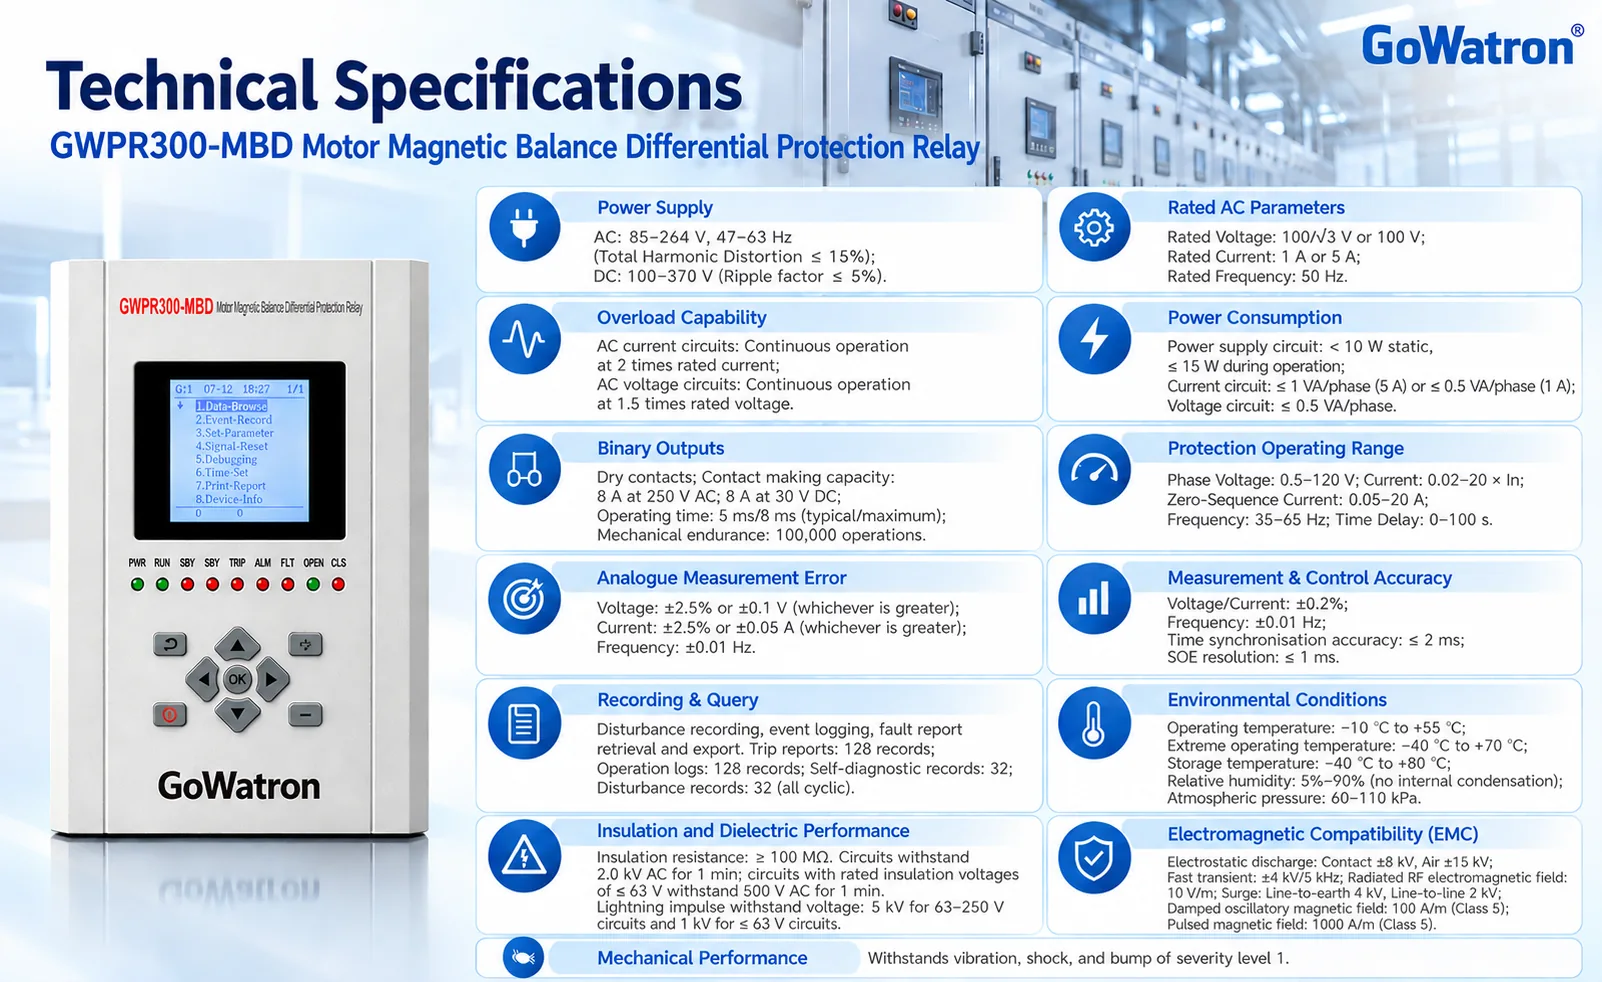
2. Technical Specifications
3. Application Scenarios
GoWatron’s GWPR300-MBD Motor Magnetic Balance Differential Protection Relay is primarily applied for the protection and control of high- and low-voltage induction motors in industrial fields such as power generation, metallurgy, petrochemicals, coal mining, water infrastructure and municipal utilities. It is installed in switchgear or protection panels and works in conjunction with current transformers (protection CTs, measurement CTs, magnetic balance CTs, zero-sequence CTs) and voltage transformers. Typical scenarios include:
- Comprehensive Protection: Protection against short circuits, overcurrent, overload, locked rotor, phase failure, earth faults, and thermal overload in motor feeder circuits. In particular, its magnetic balance differential protection (ANSI 87M) monitors differential currents measured by external magnetic balance CTs, enabling rapid detection and tripping of faults within the defined motor differential protection zone.
- Starting Management: Motor starting process management (motor starting time monitoring, motor start interval supervision, undervoltage start inhibition, and excessive starting time protection).
- Remote Monitoring: For substations or auxiliary power systems requiring remote monitoring, the GWPR300-MBD Motor Magnetic Balance Differential Protection Relay can connect to the SCADA system via dual Ethernet or RS-485 to achieve remote measurement, remote status indication, remote control, and remote setting management.
- Post-Fault Analysis: Ideal for O&M scenarios requiring disturbance recording, event logging, and fault report retrieval and export.
- Voltage and Frequency Monitoring: Suitable for industrial systems requiring monitoring of motor supply voltage, frequency, and VT circuit status. It supports overvoltage, undervoltage, overfrequency, underfrequency, VT circuit failure, and VT loss-of-voltage supervision.
- The relay features an integrated front panel and a fully enclosed housing, with physical separation between high-energy circuits and low-level signal circuits. It is designed to provide reliable protection, control and monitoring for industrial motors operating in demanding electromagnetic environments.


